Research
My research falls into three areas. Each section lists the related papers, project pages, and notes.
Simulation and generative AI for plants
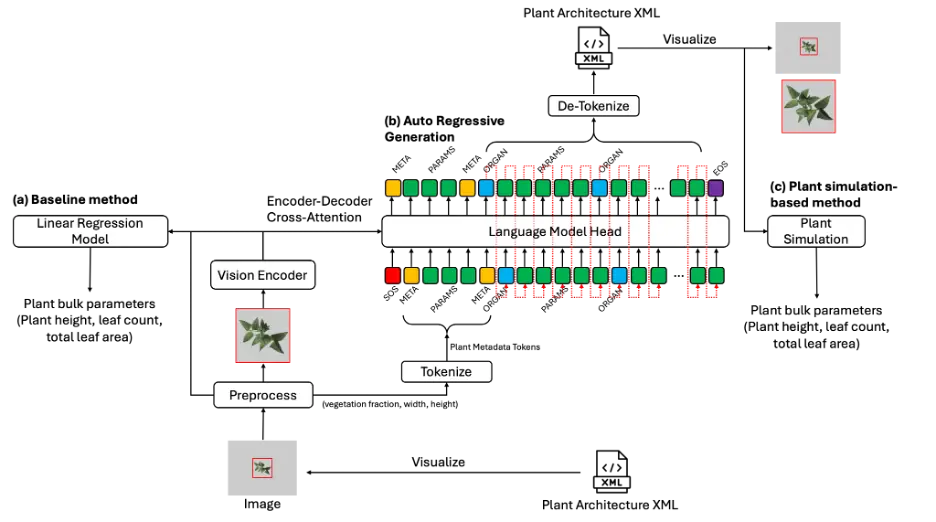
I use the Helios 3D plant simulator to generate training data for field images, and vision language models to build plant simulation models from images.
- VLM for procedural plant architecture (Frontiers in AI, 2026; code)
- VLMs for plant simulation configurations (arXiv, 2026; code)
- Botanical grammar of vision foundation models (CVPR Workshops, 2026)
- Notes on L-systems

On-device AI and field robotics
I build and test robots, UAVs, and small devices that run AI models on board in the field. Examples include a GPS-guided spray robot for vineyards and a weed monitor that runs a quantized classifier on a Raspberry Pi AI camera.
- Robo-ag: autonomous targeted spraying (Farm Robotics Challenge, 2023; code)
- WeedTrackr: edge AI weed monitoring (AIFS × Sony AI AgTech Challenge, 2025)
- Research UAV build and LiDAR and GPS interference on a UAV
- ASABE 2026 Student Robotics Challenge team
Thermal and multimodal sensing
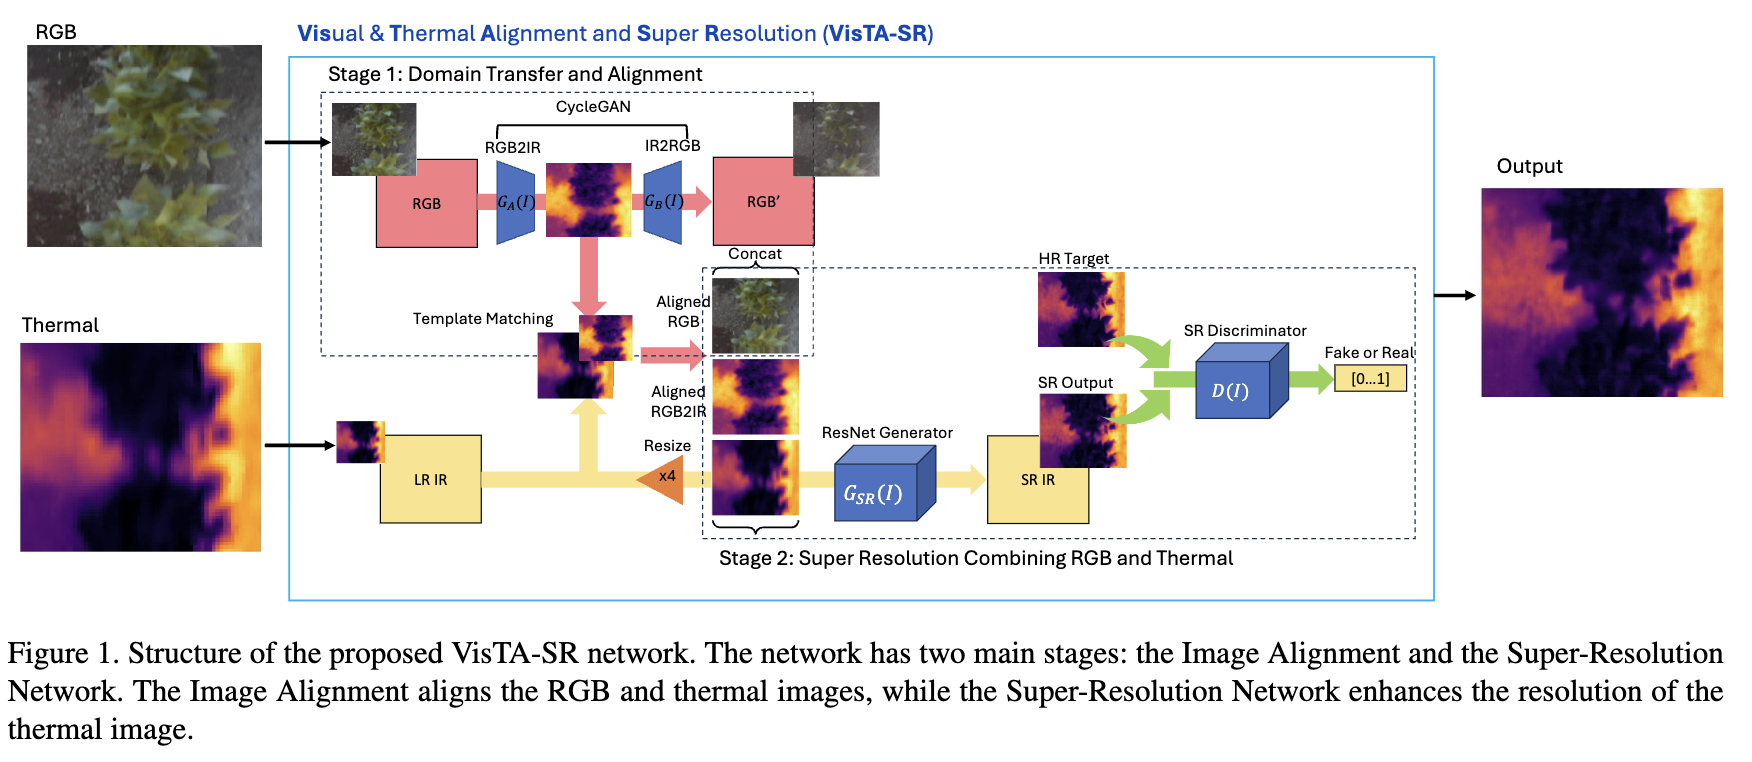
Low-cost thermal cameras make canopy temperature measurement affordable, but their images are low resolution and less accurate. I work on improving them with RGB images, and on combining thermal, RGB, and other sensors to estimate plant water status and traits.
- VisTA-SR thermal super-resolution (CVPR Workshops, 2024; code)
- Thermal image segmentation in weedy fields (Plant Phenomics, 2026)
- Stomatal conductance from thermal imagery (Journal of Experimental Botany, 2026)
- Multimodal sensing of basil water stress (Agronomy, 2025)
- Smartphone app for leaf angle measurement
Earlier work
At Seoul National University I worked on UAV remote sensing of upland crops (radiometric calibration, growth and biomass estimation) and built a weighing system for forest evapotranspiration, which was also used in a patented forest fire prevention system. From 2017 to 2021 I was a software engineer at A.I.MATICS, working on computer vision for driver monitoring, from embedded processors in vehicles to cloud processing on AWS.